Davood Soleymanzadeh
I'm a Ph.D. student in the J. Mike Walker ’66 Department of Mechanical Engineering at Texas A&M University, advised by Professor Minghui Zheng in the Control and Robotics Lab. I work at the intersection of robot learning and manipulation — learning-based motion planning, vision-language-action models, world models, and tactile, contact-rich manipulation.
Before robot learning, I worked on nonlinear and sensorless control of piezoelectric actuators at Amirkabir University of Technology.
Updates
- Jun 2026 “GAIDE: Graph-based Attention Masking for Spatial- and Embodiment-Aware Motion Planning” was accepted to IROS 2026!
- Mar 2026 “Modular Safety Guardrails Are Necessary for Foundation-Model-Enabled Robots in the Real World” was accepted as a Position Paper at ICML 2026!
- Feb 2026 Our survey, “Towards Generalist Neural Motion Planners for Robotic Manipulators: Challenges and Opportunities”, was accepted to IEEE Transactions on Automation Science and Engineering (T-ASE)!
- Feb 2025 “SIMPNet: Spatial-Informed Motion Planning Network” was published in IEEE Robotics and Automation Letters (RA-L)!
- Jan 2024 I joined Texas A&M University to continue my Ph.D. with Professor Minghui Zheng.
- Aug 2023 I started my Ph.D. at University at Buffalo with Professor Minghui Zheng.
Selected Publications
Selected work in robot learning, motion planning, vision-language-action models, and contact-rich manipulation.
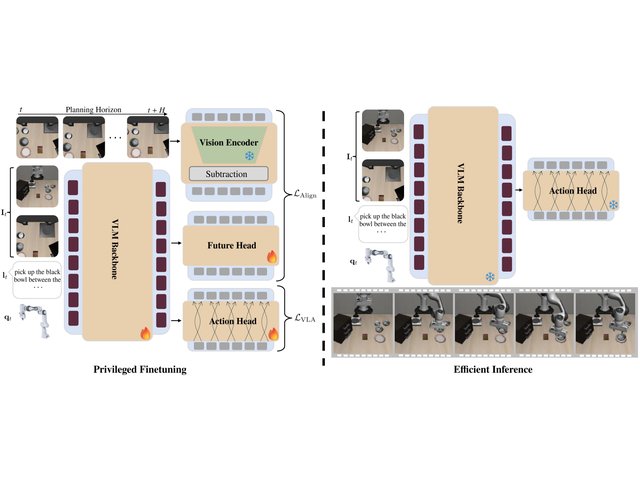
Davood Soleymanzadeh, Kaidi Zhang, Zhiyuan Zhang, Bihao Zhang, Xiao Liang, Yu She, Minghui Zheng
arXiv preprint, 2026
Introduces privileged future-dynamics supervision to help vision-language-action models reason over planning horizons for fine-grained, contact-rich manipulation.
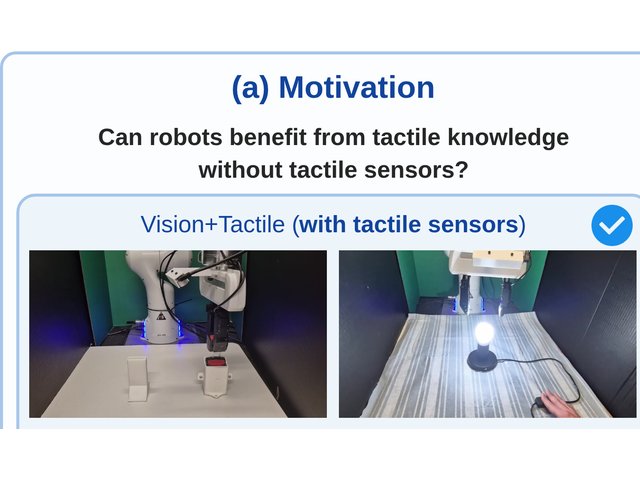
Zhiyuan Zhang, Adeesh Desai, J. C. Hu, Y. Saka, Q. K. Luu, Jiuzhou Lei, Davood Soleymanzadeh, et al.
arXiv preprint, 2026
Predicts tactile representations from vision and proprioception so manipulation policies can benefit from tactile knowledge without tactile sensors at deployment.
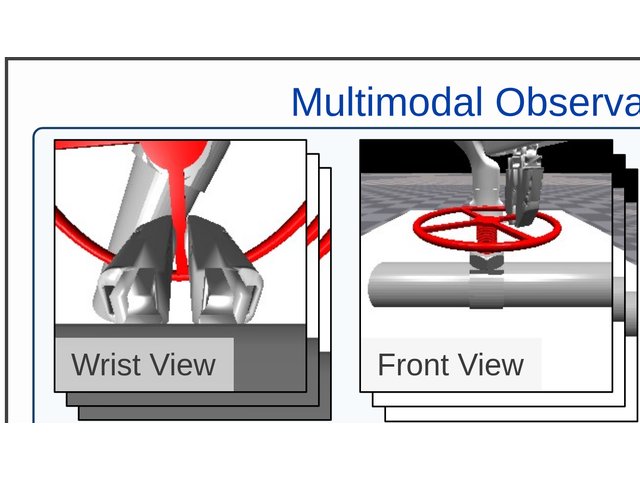
Zhiyuan Zhang, P. Zhou, Kaidi Zhang, Adeesh Desai, T. Amosa, Davood Soleymanzadeh, Jiuzhou Lei, et al.
arXiv preprint, 2026
Studies vision-tactile world-model representations across 12 contact-rich manipulation tasks and identifies spatial structure, temporal continuity, and cross-modal compatibility as key factors.
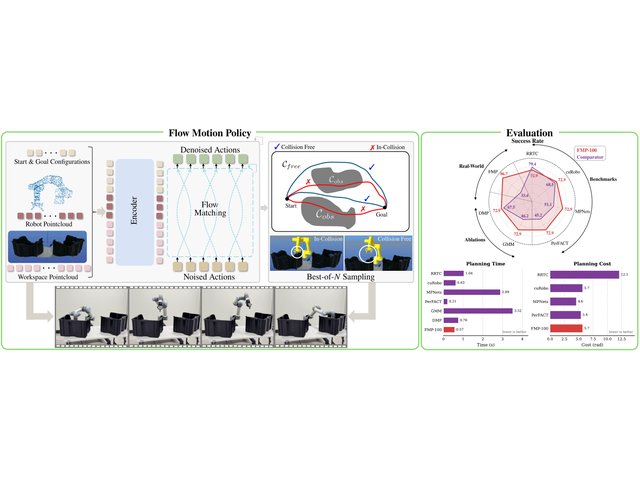
Davood Soleymanzadeh, Xiao Liang, Minghui Zheng
Under Review, IEEE Transactions on Robot Learning
Uses flow matching to generate multiple candidate manipulator motion plans, enabling efficient best-of-N inference without iterative collision checking.
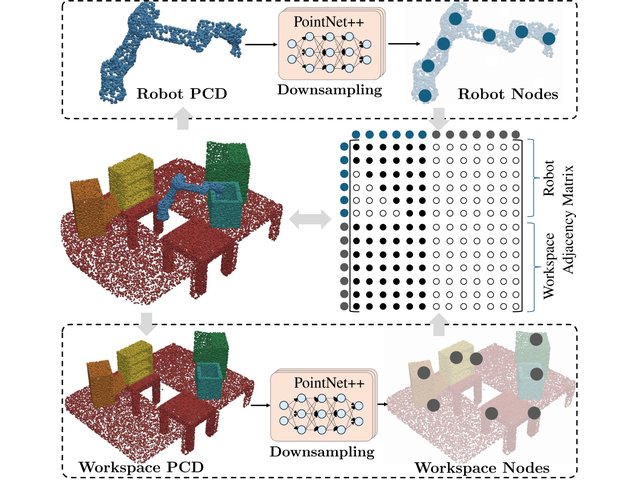
Davood Soleymanzadeh, Xiao Liang, Minghui Zheng
International Conference on Intelligent Robots and Systems (IROS 2026)
Encodes the spatial structure of a planning problem and the robot's embodiment through graph-based attention masking for neural informed sampling.
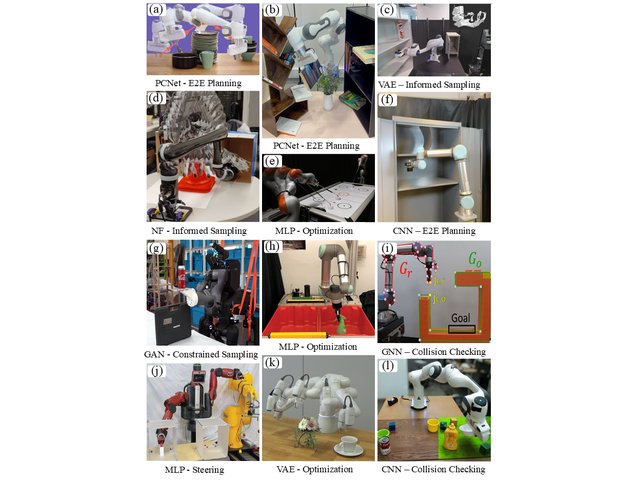
Davood Soleymanzadeh, I. Lopez-Sanchez, H. Su, Y. Li, Xiao Liang, Minghui Zheng
IEEE Transactions on Automation Science and Engineering, 2026
Surveys deep-learning approaches for robotic-manipulator motion planning and discusses open challenges in generalization, safety, data, and evaluation.
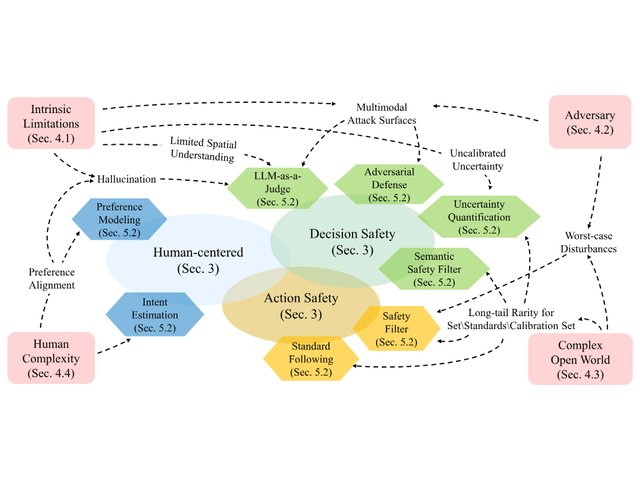
J. Kim*, W. Chen*, Davood Soleymanzadeh*, Y. Ding, X. Gao, Z. Tu, R. Zhang, et al.
Forty-third International Conference on Machine Learning, Position Paper Track, 2026
Argues for modular monitoring and intervention layers to provide action, decision, and human-centered safety for foundation-model-enabled robots.
* indicates equal contribution
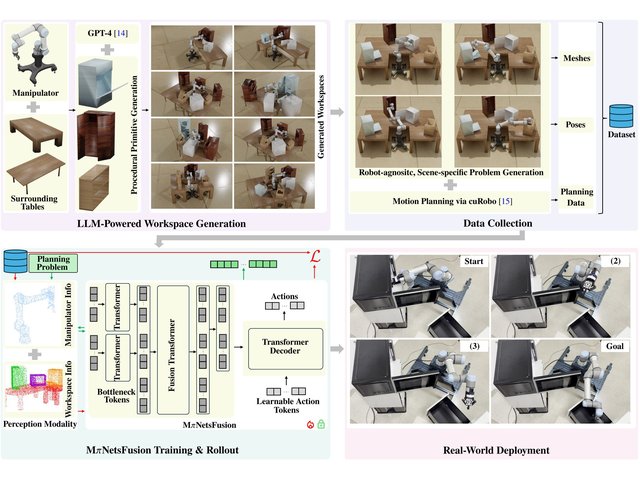
Davood Soleymanzadeh, Xiao Liang, Minghui Zheng
Under Review, IEEE Transactions on Robotics
Combines LLM-powered workspace synthesis with a fusion action-chunking transformer to train a more generalist motion policy from 3.5 million trajectories.
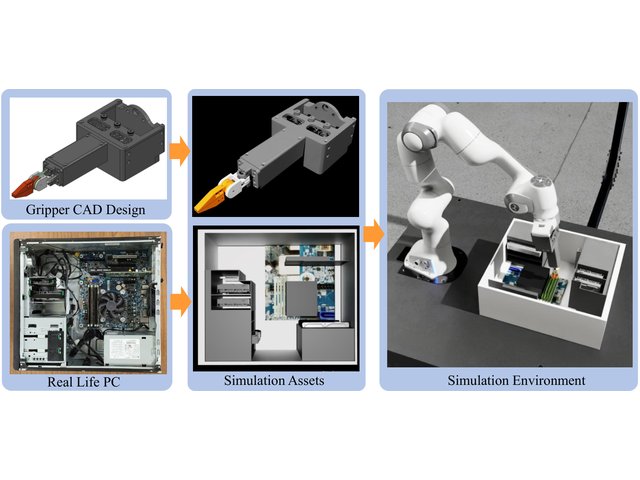
B. Zhang, Davood Soleymanzadeh, Xiao Liang, Minghui Zheng
arXiv preprint, 2025
Presents a compact cable-driven robotic gripper designed for desktop-scale disassembly tasks.
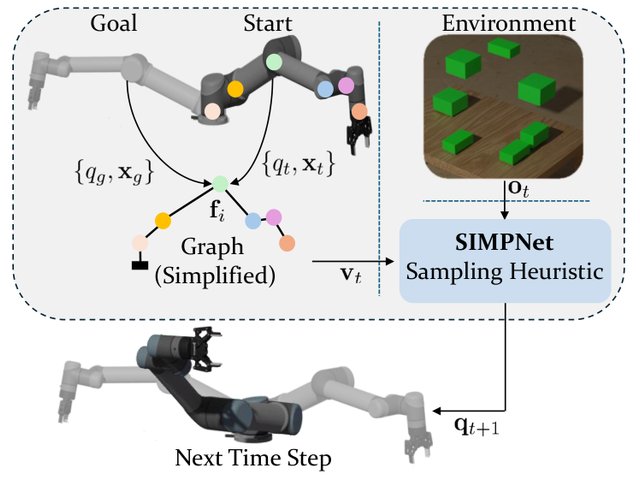
Davood Soleymanzadeh, Xiao Liang, Minghui Zheng
IEEE Robotics and Automation Letters, 2025
Uses a stochastic graph-neural-network sampling heuristic and cross-attention to encode workspace and manipulator structure for sampling-based motion planning.